Products built for diagnostics, control, autonomy, and training.
Explore the Skynacues Intellectics portfolio in one place, with each product mapped to its role, maturity, and operational value.
Parametric-X
Aircraft Parameter Control
Compare incoming aircraft parameters against an approved baseline, review every delta, and publish traceable revisions.
- Precision comparisonSee changed, added, removed, and unchanged values with units and descriptions.
- Controlled revisionsKeep immutable server history, release notes, independent approvals, and audit records.
- Protected workspaceUse encrypted local baselines with role-gated access and verified file integrity.
DroneTools & WebTools
UAV Diagnostic Intelligence
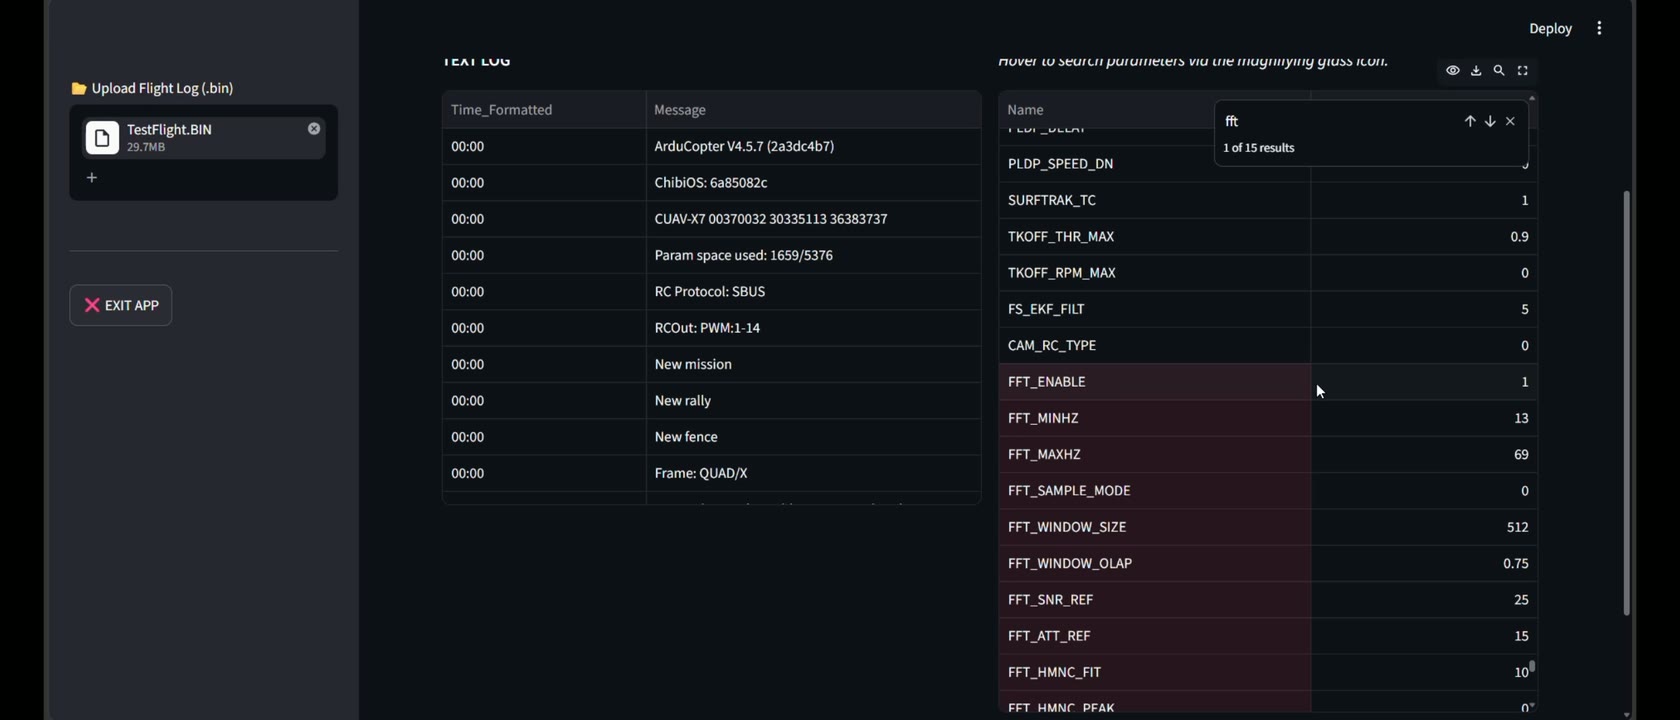
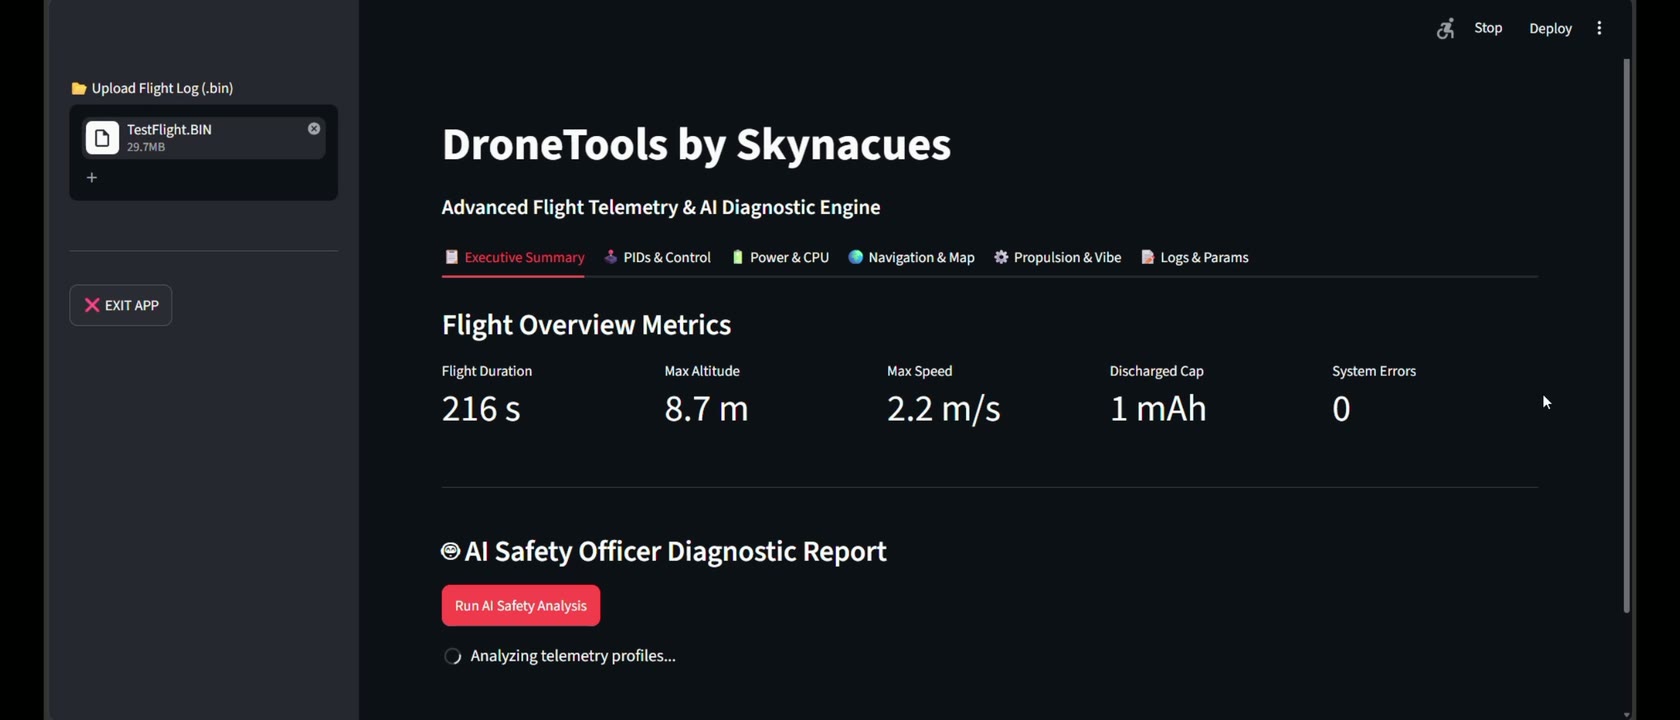
The same UAV diagnostic core, delivered as WebTools in the browser or DroneTools as a secure offline desktop application.
- WebTools / SaaSUpload logs in a browser, browse parameters, and generate watermarked reports.
- DroneTools / StandaloneRun deployable field diagnostics offline with pre/post-flight reports and log analysis.
- Shared diagnostic coreMove from mission planning and visualization to system diagnostics in one product family.
Liftware
Ground Control Console
Liftware is an Electron ground-control console for carefully gated live-vehicle testing.
- Simulation & Live LinksStart ArduPilot SITL or connect to a verified vehicle over TCP, UDP, or Serial.
- MAVLink Flight DeckMonitor telemetry and send Guided, Arm, Takeoff, RTL, and map-click target commands.
- Mission & Terrain ControlLock World Terrain, add map-click waypoints, and upload AUTO missions.
Autonom-X
The Digital Proving Ground
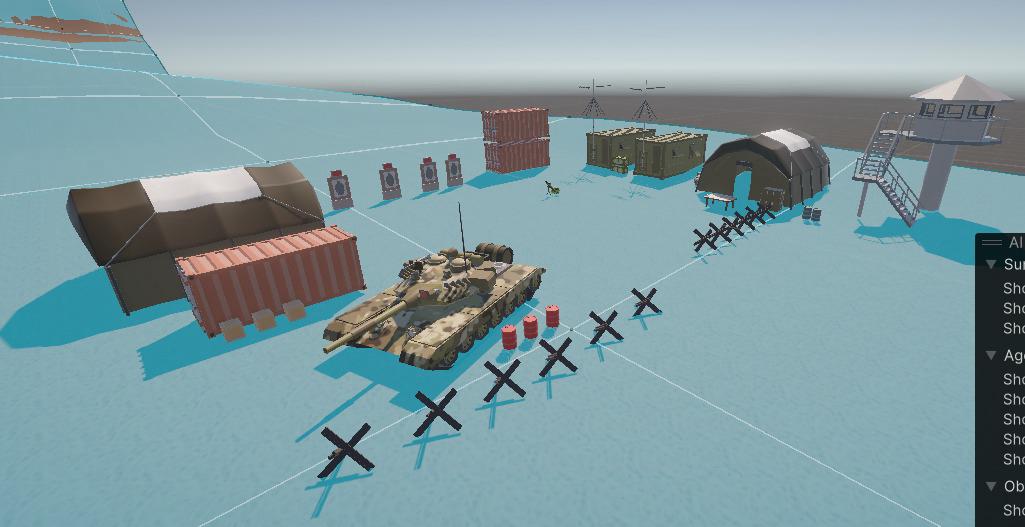
Autonom-X is a high-fidelity simulation and validation ecosystem built on Unreal Engine 5.
- Advanced Autonomy SandboxRapidly prototype and validate LUA and Python scripts.
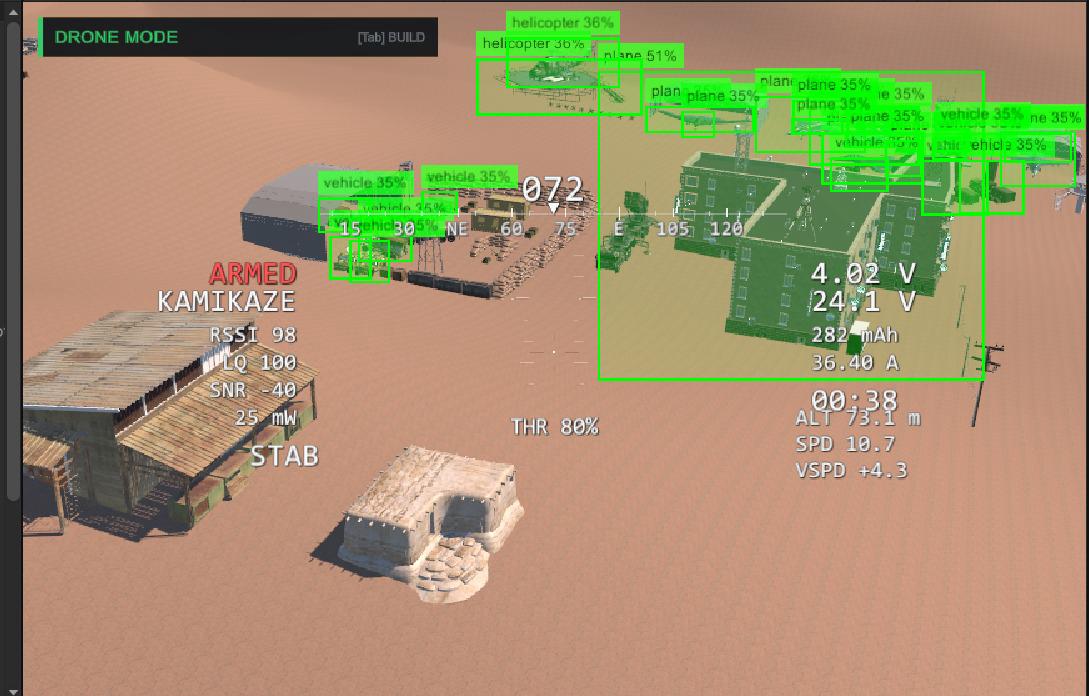
- AI & Computer Vision LabNative support for OpenCV model validation.
- Pilot & Payload TrainingPractice aircraft handling and payload timing in a zero-risk environment.
GNSS Denied Navigation
GNSS-Denied Navigation (TERCOM + DSMAC)
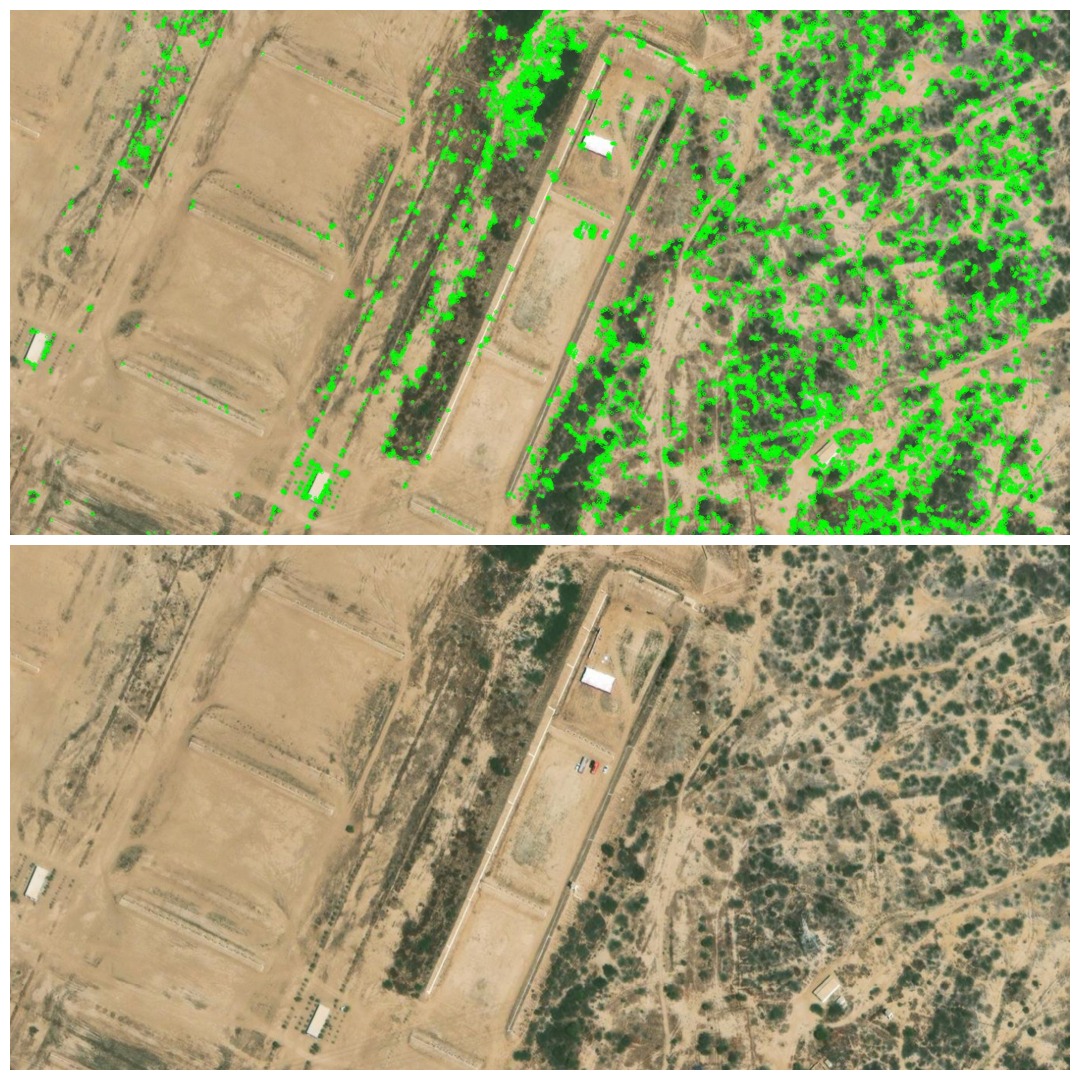
A ROS2/Gazebo navigation environment combining TERCOM (Terrain Contour Matching) with DSMAC visual scene correlation for autonomous position estimation when GNSS is denied.
- TERCOM + DSMAC FusionMatch terrain contours and visual scenes to support autonomous location lock without GNSS.
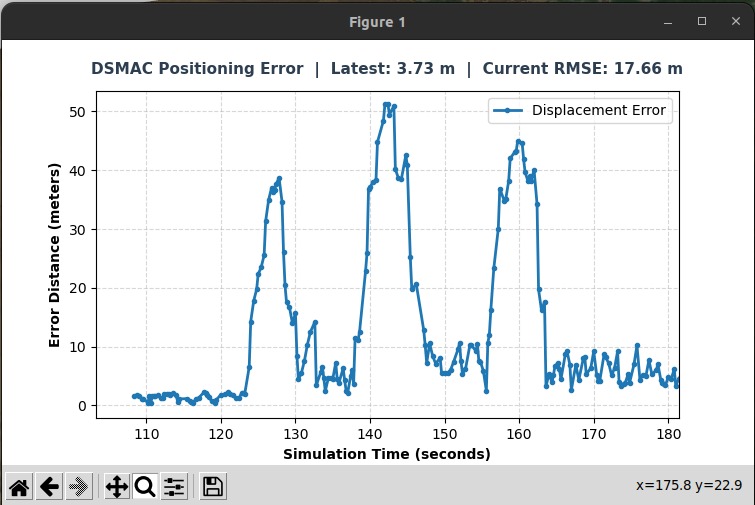
- DSMAC Positioning ReviewInspect displacement-error traces from visual scene-matching simulation runs.
- ROS2 + Swarm RuntimeValidate terrain matching, leader-follower coordination, and encrypted fleet links.
AutoPilot Flight Controller & ESAD
Indigenous Autopilot + ESAD Systems
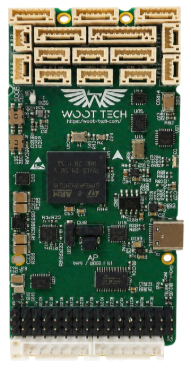
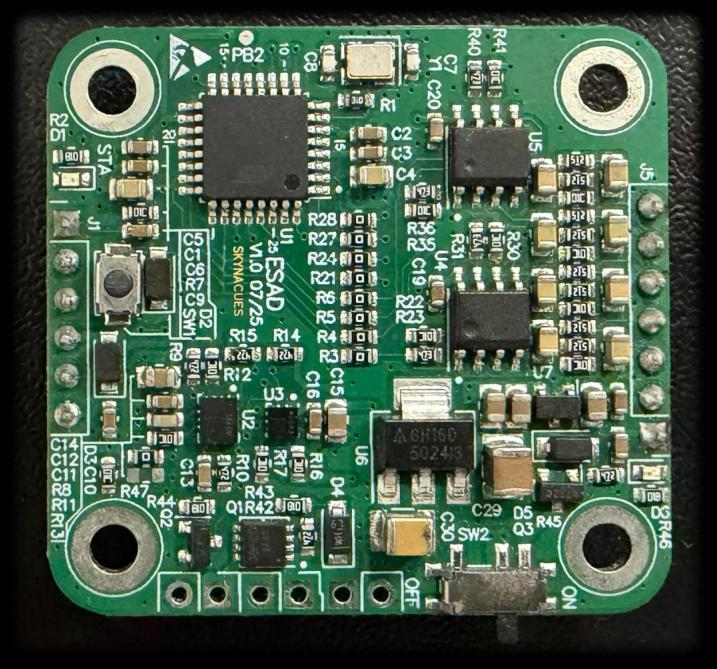
A compact, indigenously developed 8-layer autopilot PCB with ArduPilot and PX4 firmware integration, paired with an ultra-compact ESAD safety module for multi-protocol UAV systems.
- Walnut 8-Layer PCBA compact 42 x 100 mm flight-controller board with dedicated signal, ground, and power layers.
- Multi-Protocol UAV I/OGPS, CAN, I2C, SPI, UART/telemetry, ST-Link/SWD, and integrated battery sensing support.
- ArduPilot + PX4 FirmwareIntegrated firmware support for the profile's listed autopilot stacks.
- ESAD Safety ArchitecturePhysical switches, micro-controller validation, and dual-gated solid-state triggers in an ultra-compact module.